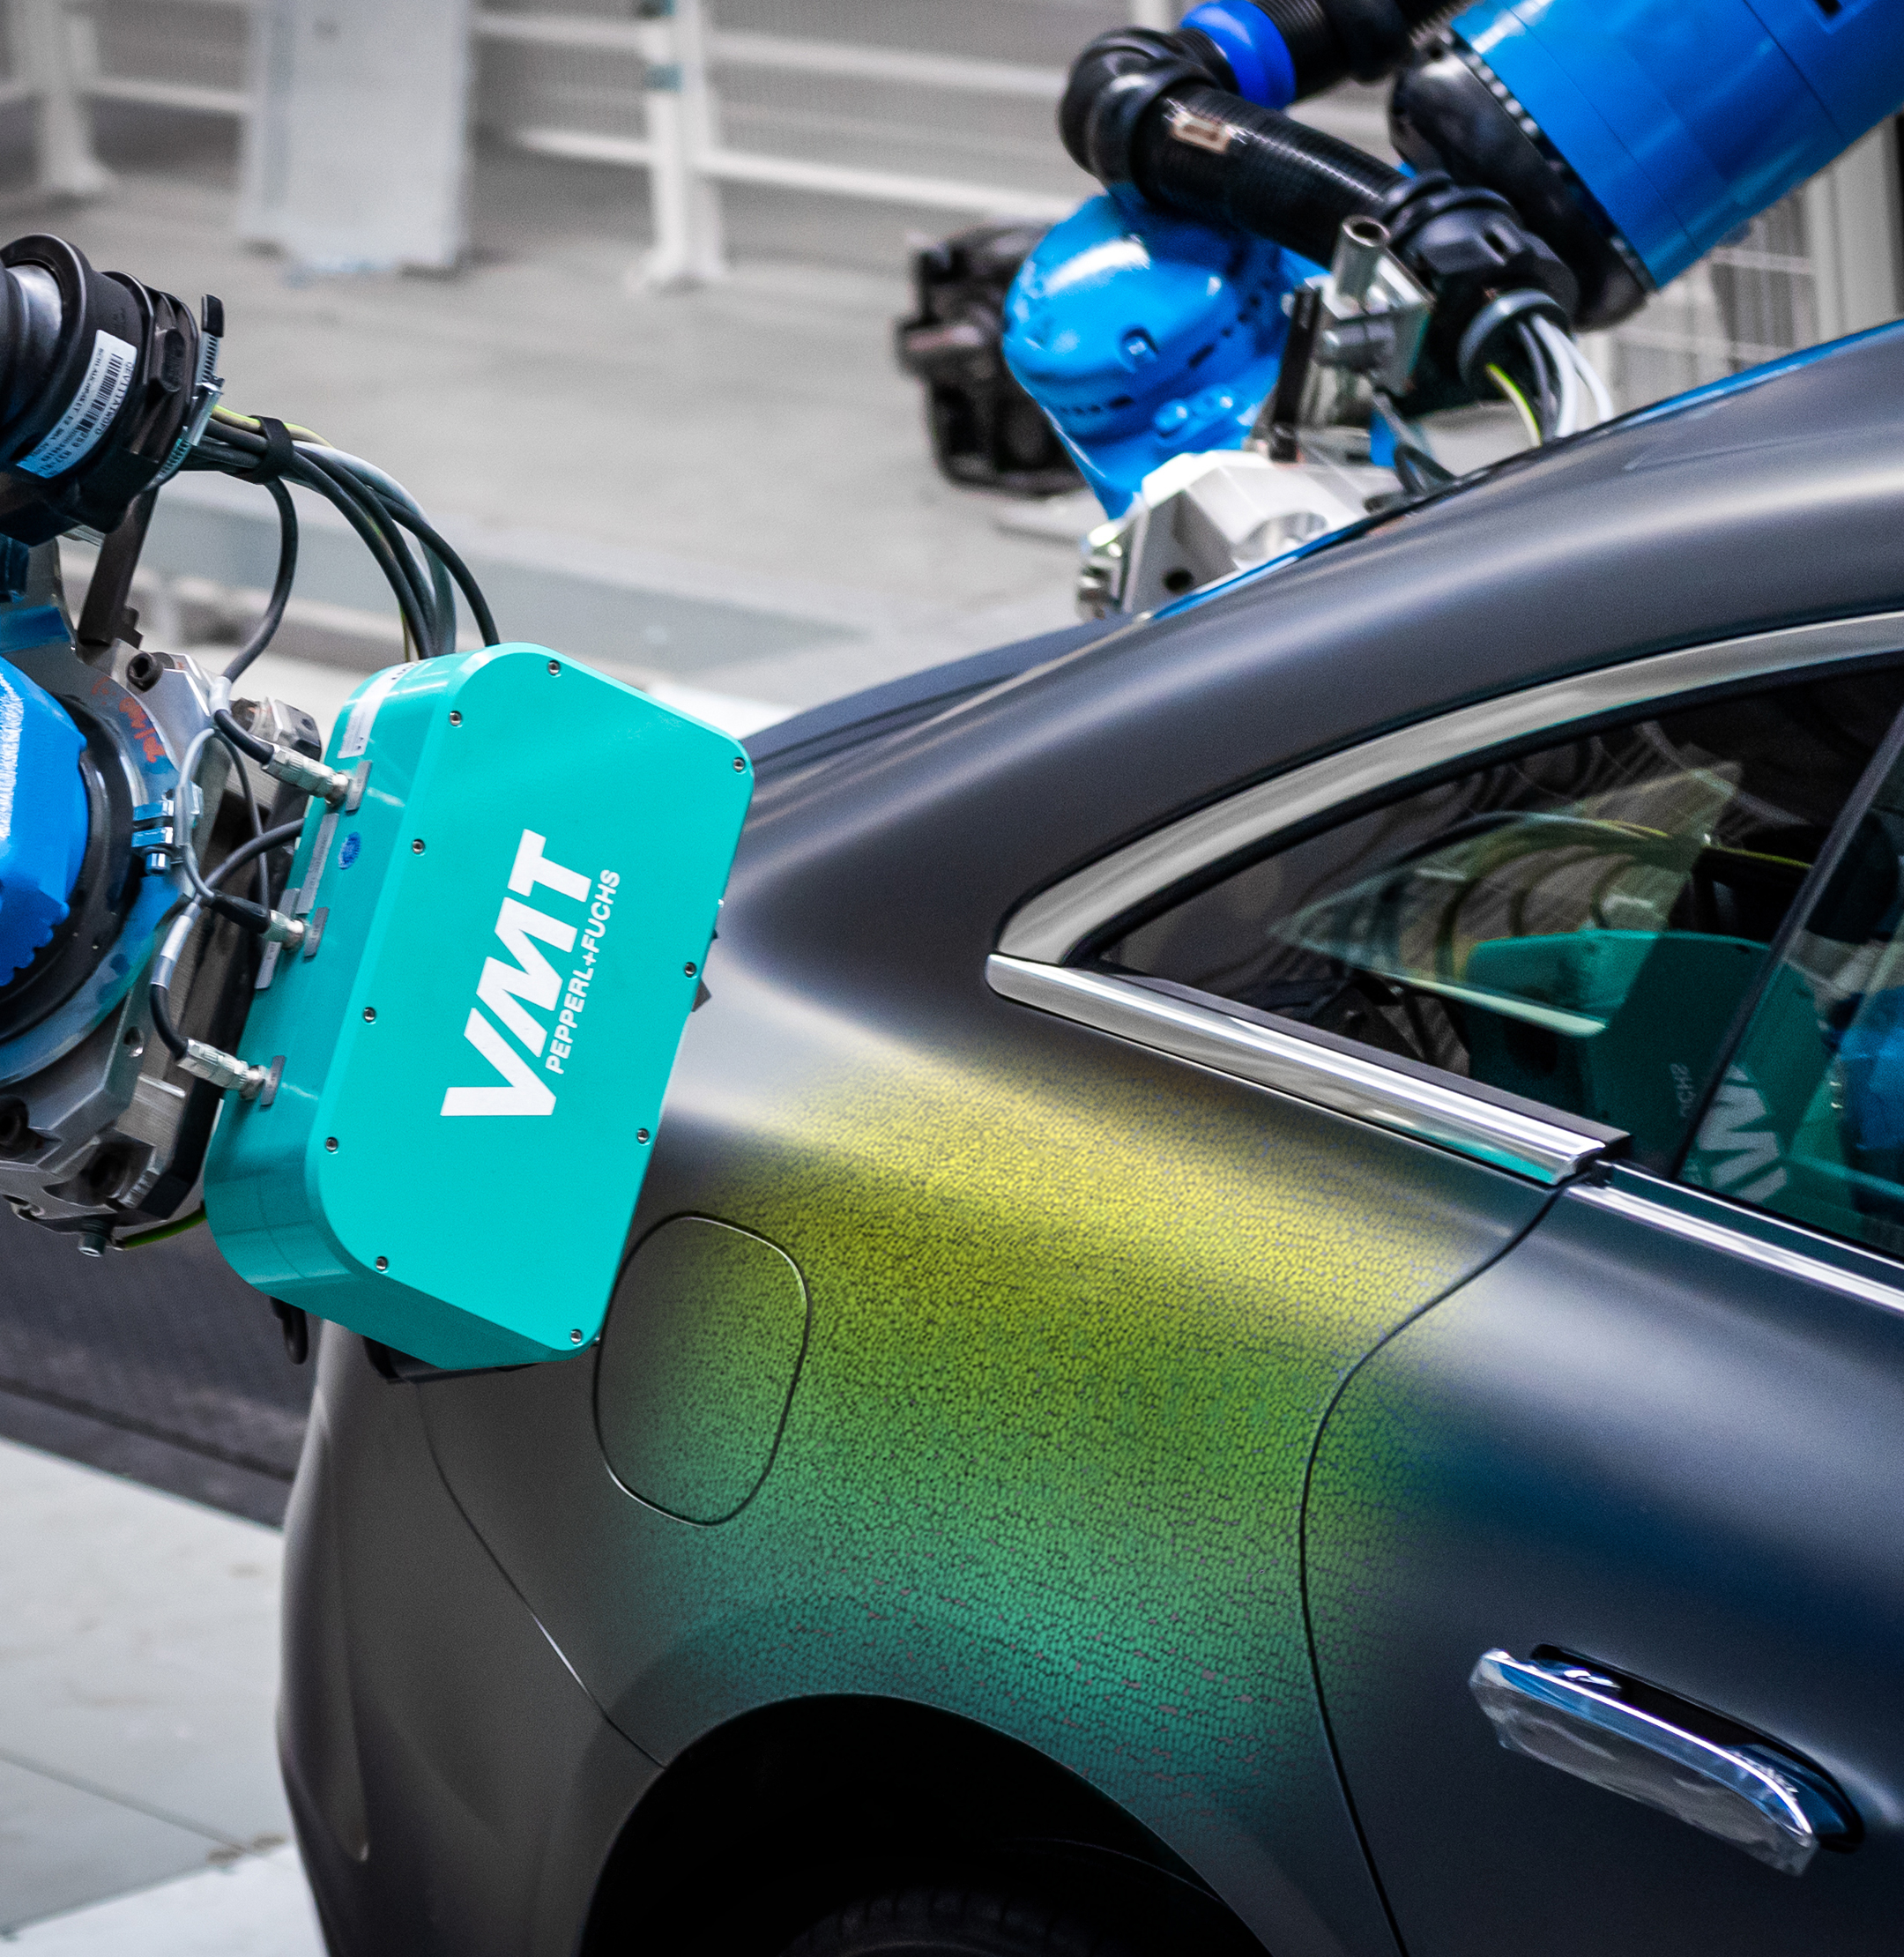
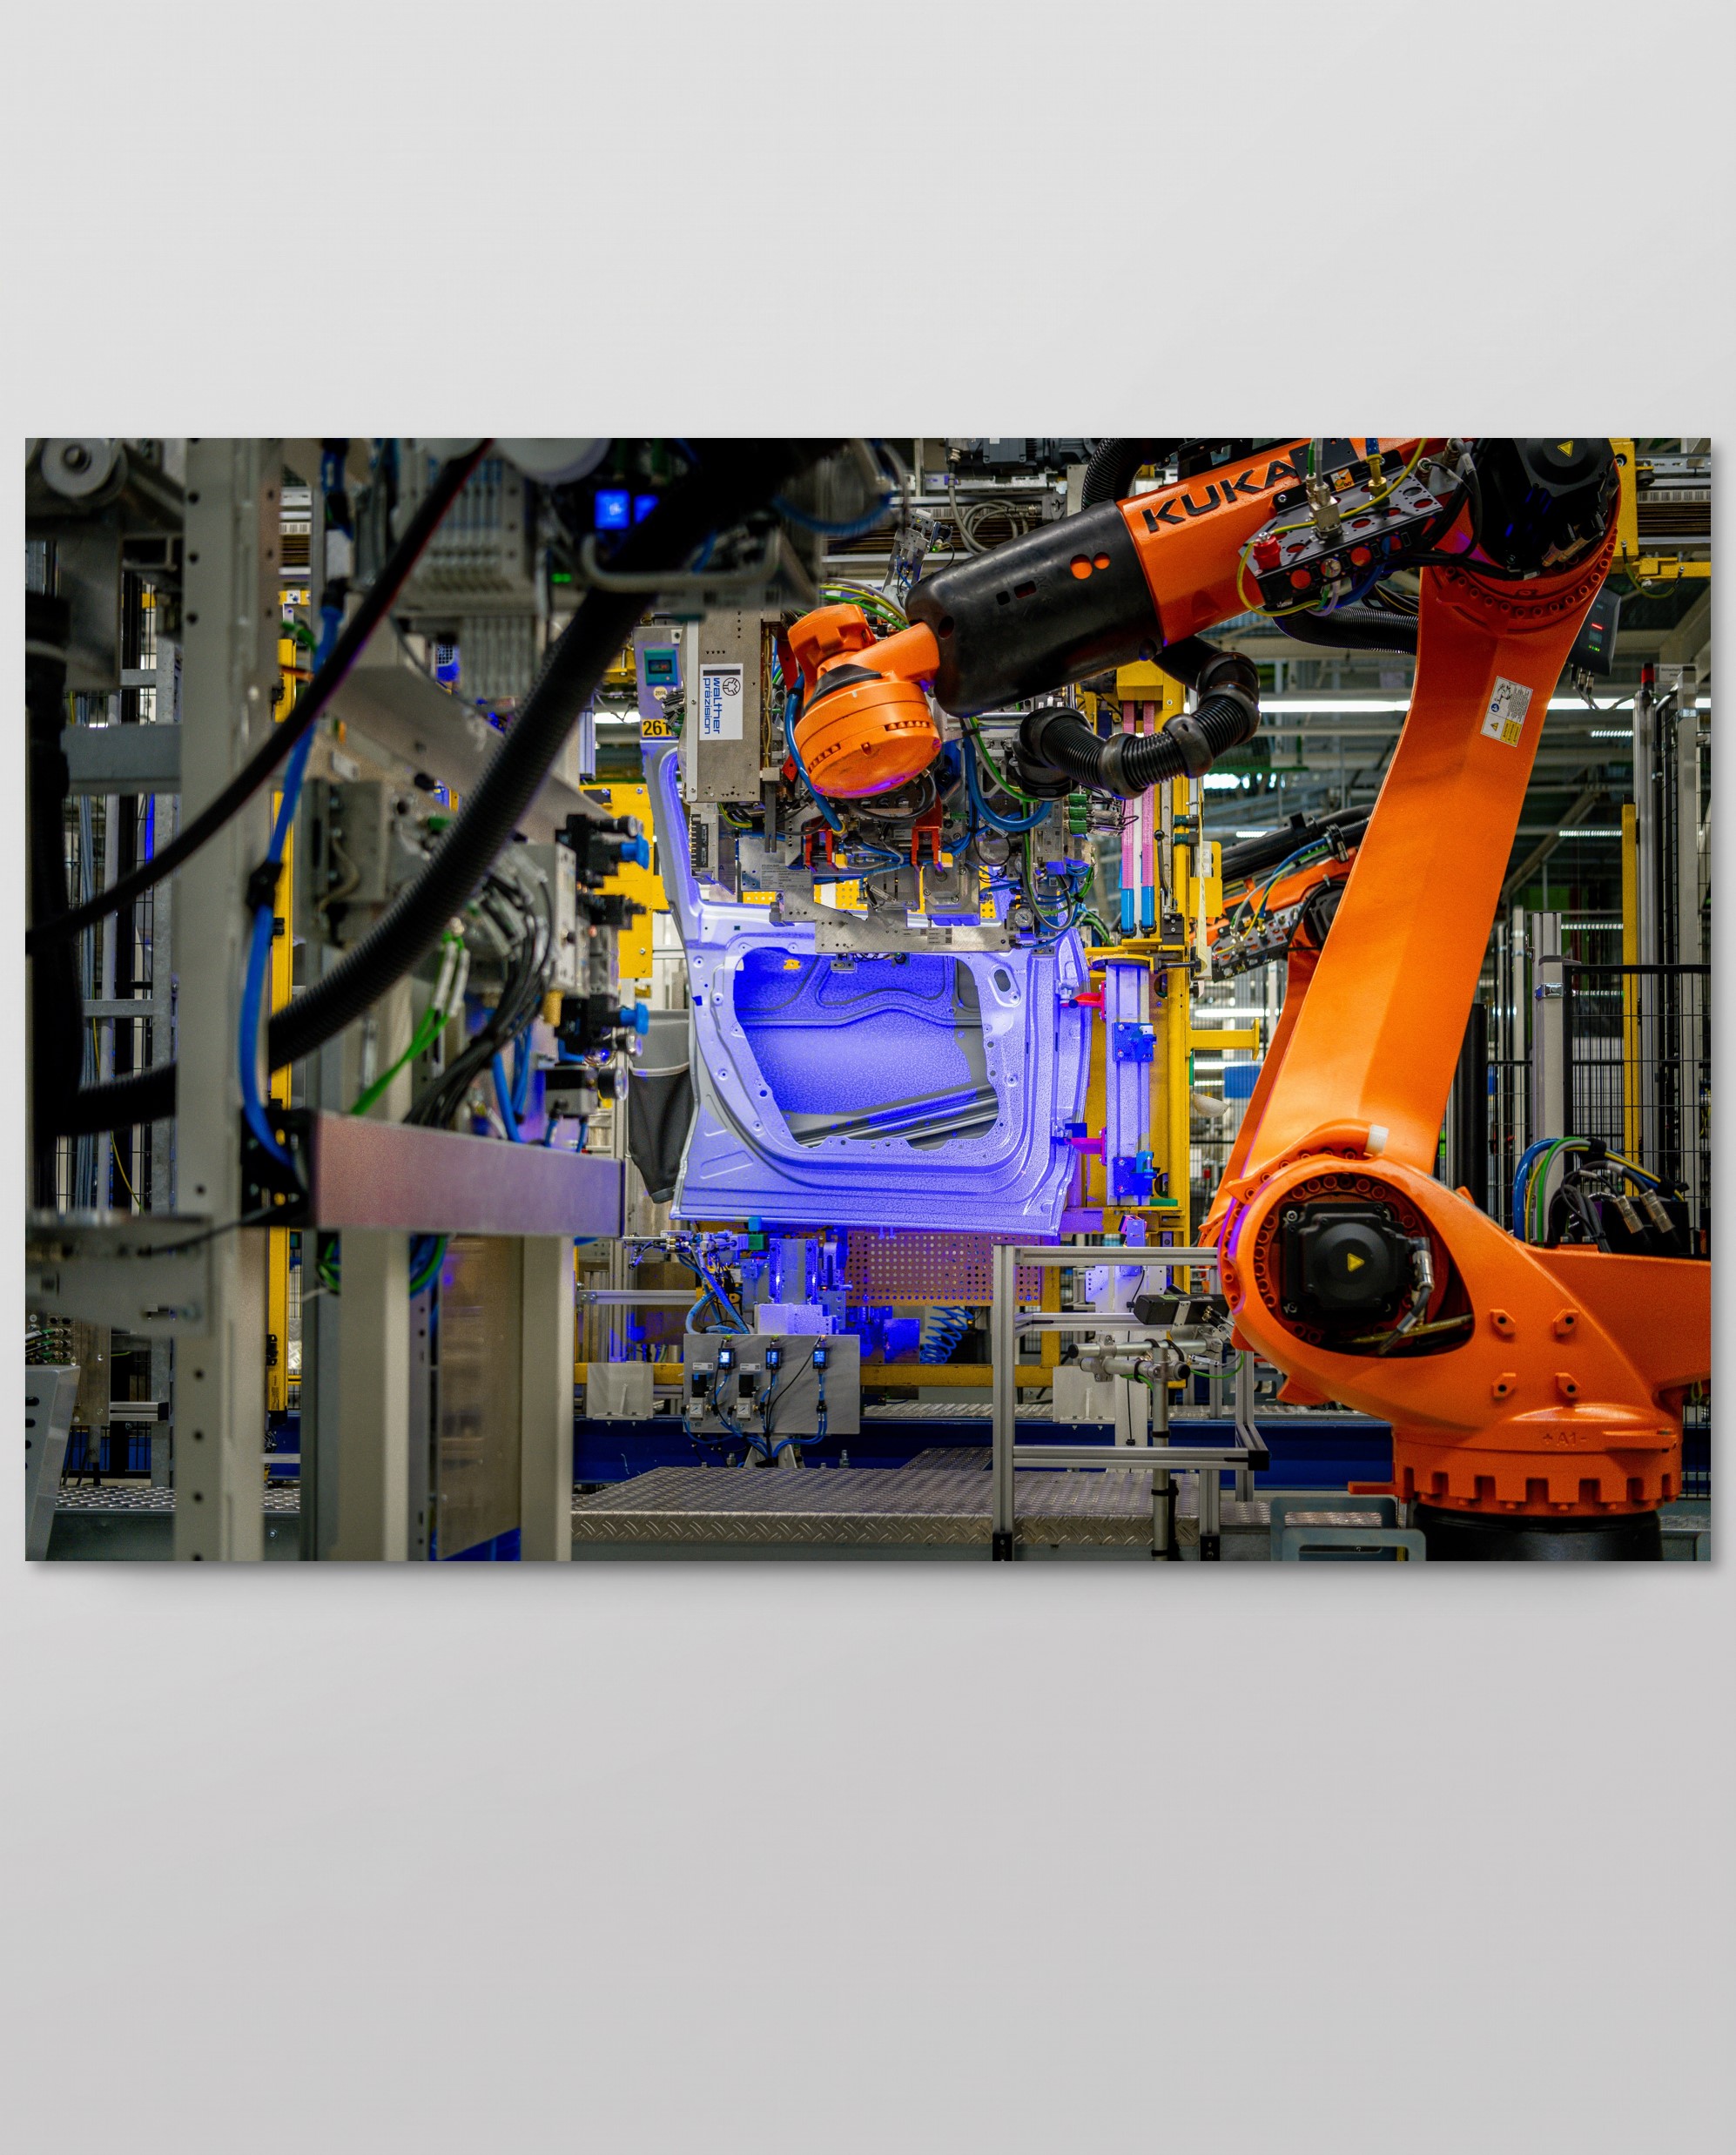
When components are only loosely positioned – hanging on a carrier, sitting in a bin, or held in a gripper – handling processes cannot rely on a fixed placement position. VMT OSC solves this by capturing a full 3D point cloud of the component and matching it against its CAD model, delivering a precise position correction directly to the robot regardless of where the part currently is.
Fully Automatic Positioning
Solves positioning problems without manual setup or teaching
High Accuracy
Down to <0.2 mm depending on sensor configuration
Flexible Integration
Scalable in sensor size, type, and number; combinable with other VMT technologies
How it works
Point Cloud Capture & CAD Matching
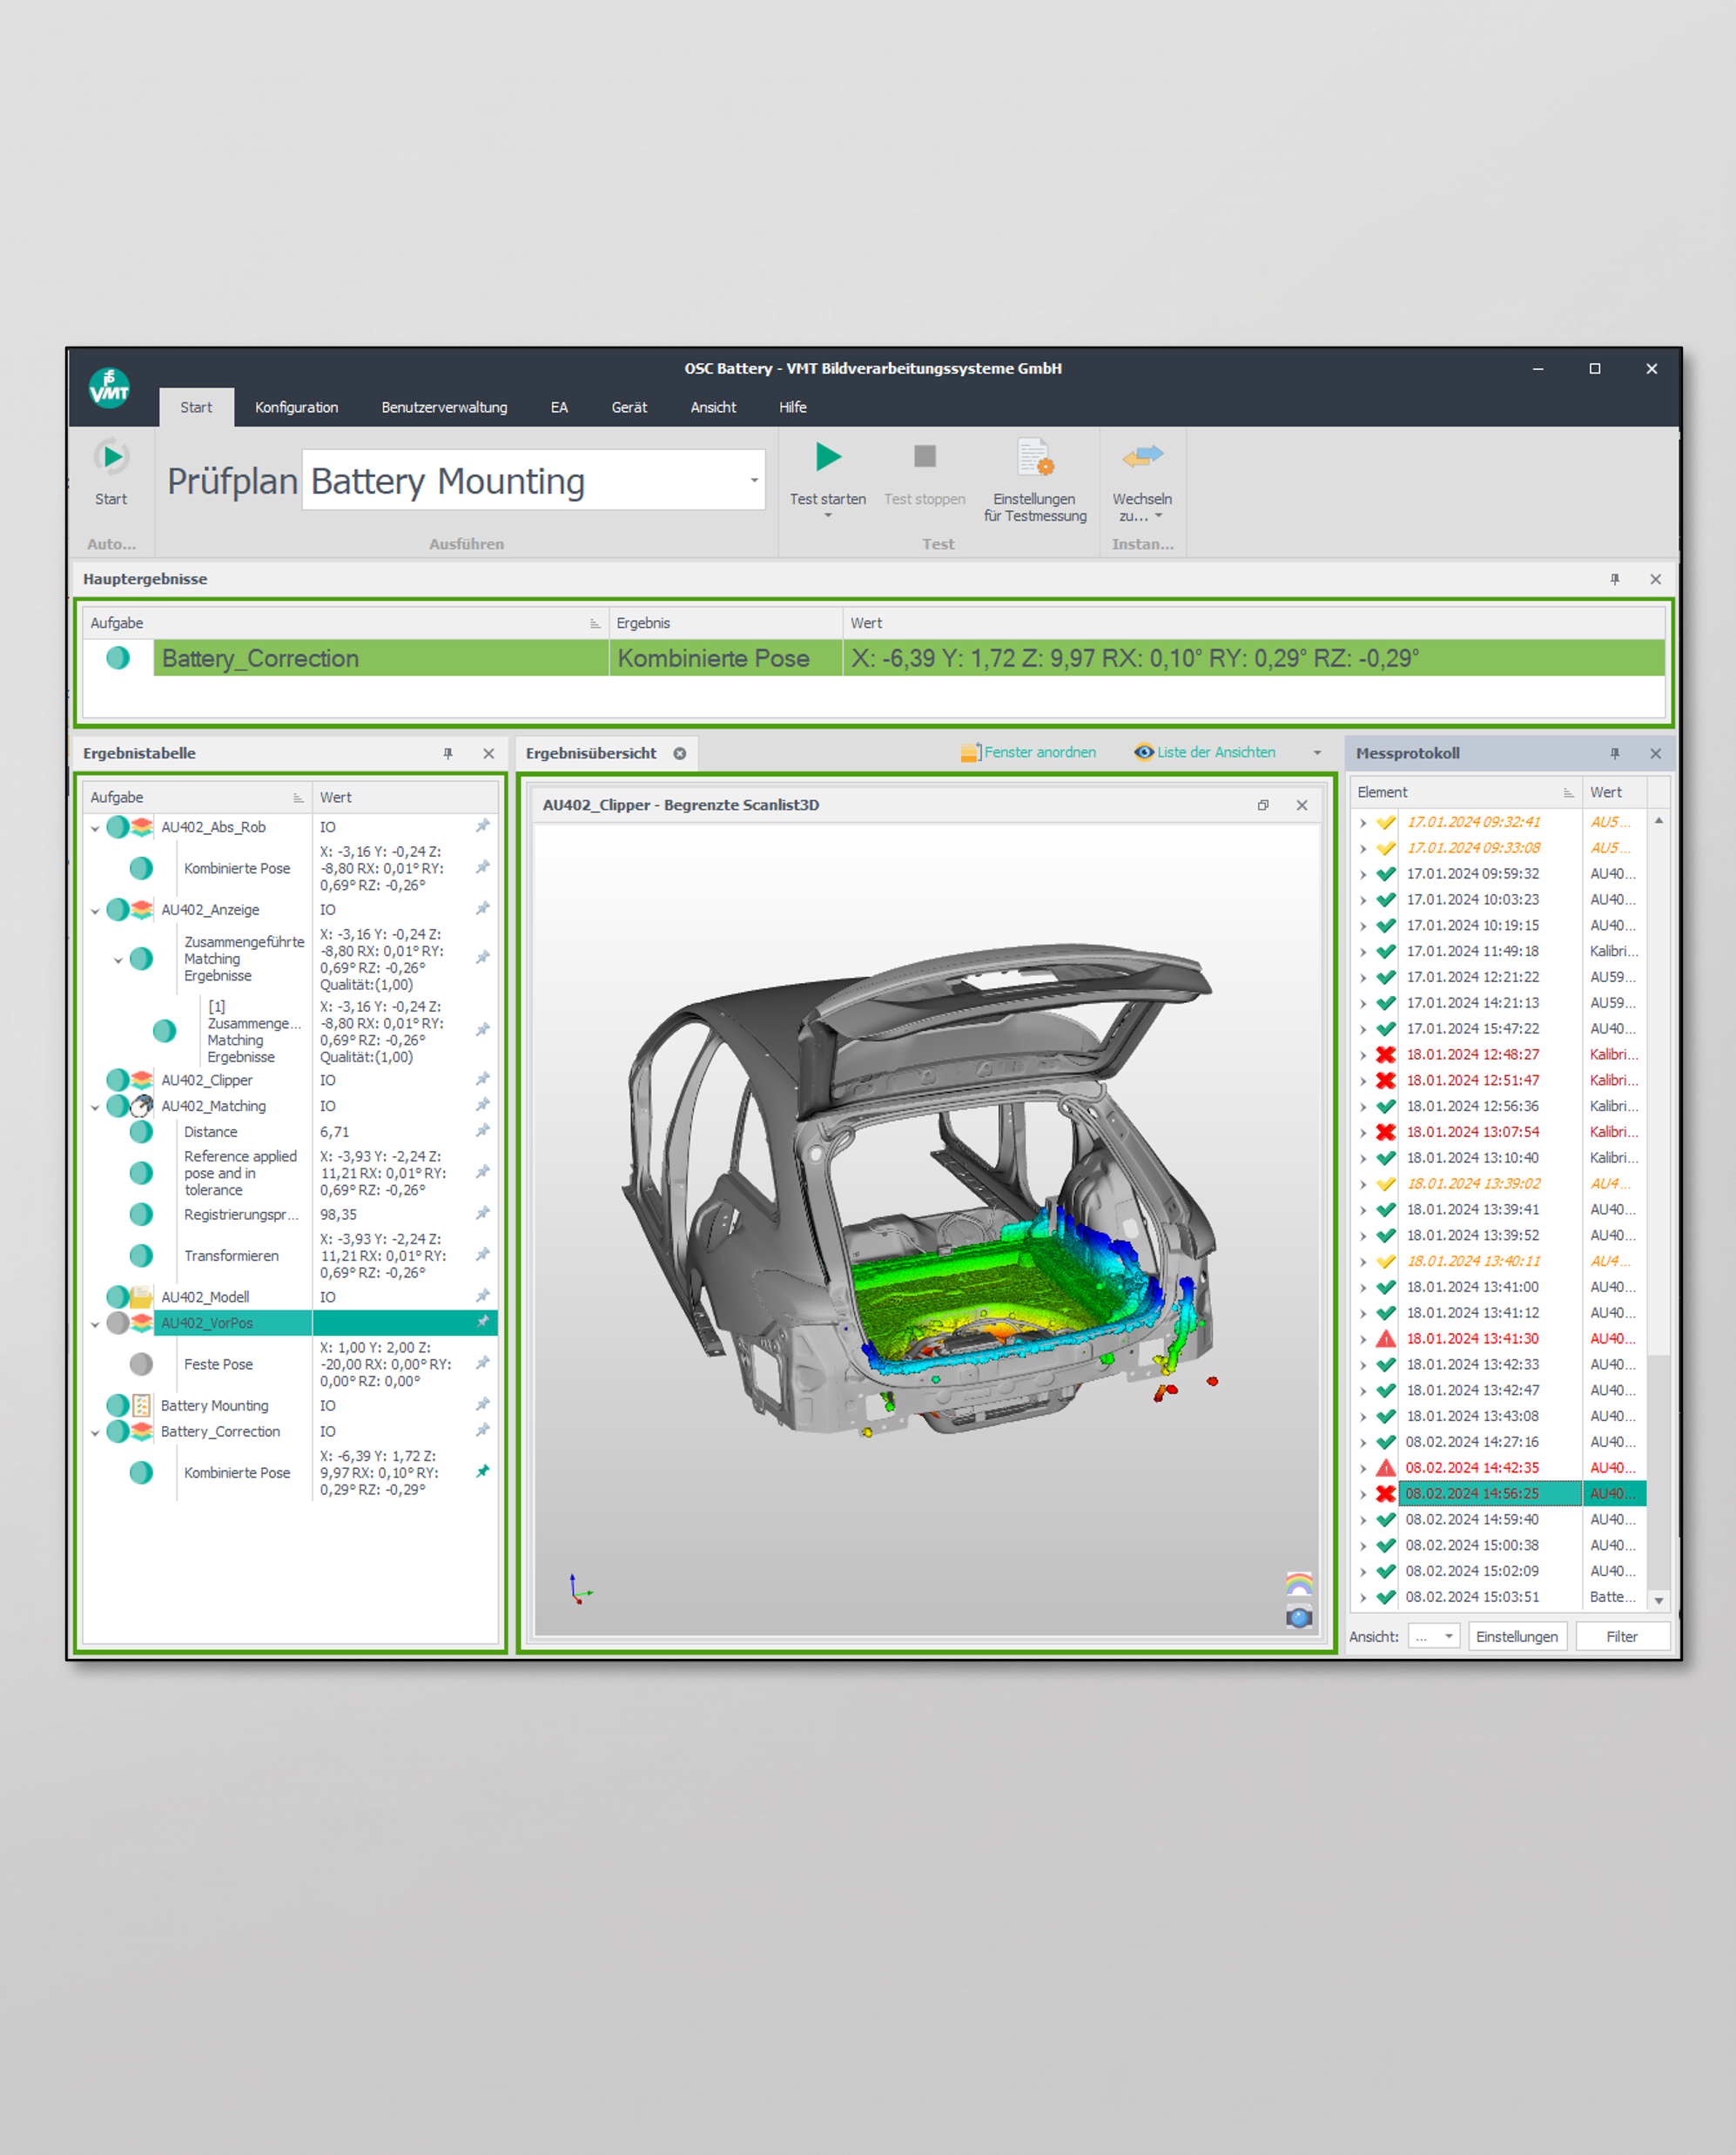
Millions of individual 3D points are combined into a point cloud, which is matched against the component's CAD reference model to determine its actual position and orientation.
Position Determination via Point Cloud Registration (PCR)
The system detects the object through surface matching rather than dedicated features, calculating position in the robot's tool or base coordinate system.
Direct Robot Correction
The resulting position or displacement vector is passed directly to the robot for accurate handling or assembly.
01
How it works
Software & Control
VMT MSS Software Platform
Visualizes the point cloud and CAD match, displays the main result (e.g. 3D position as base correction), and supports native interfaces to robot controllers, cell control systems, and cloud servers.
Fast Type Integration
New component variants are added simply by loading a new CAD reference model, without retraining individual features.
Automatic Calibration
Ball-plate calibration methods realign the coordinate system after a sensor exchange; search areas adjust automatically, with no manual re-teaching required.
02
Software & Control
Hardware & Integration
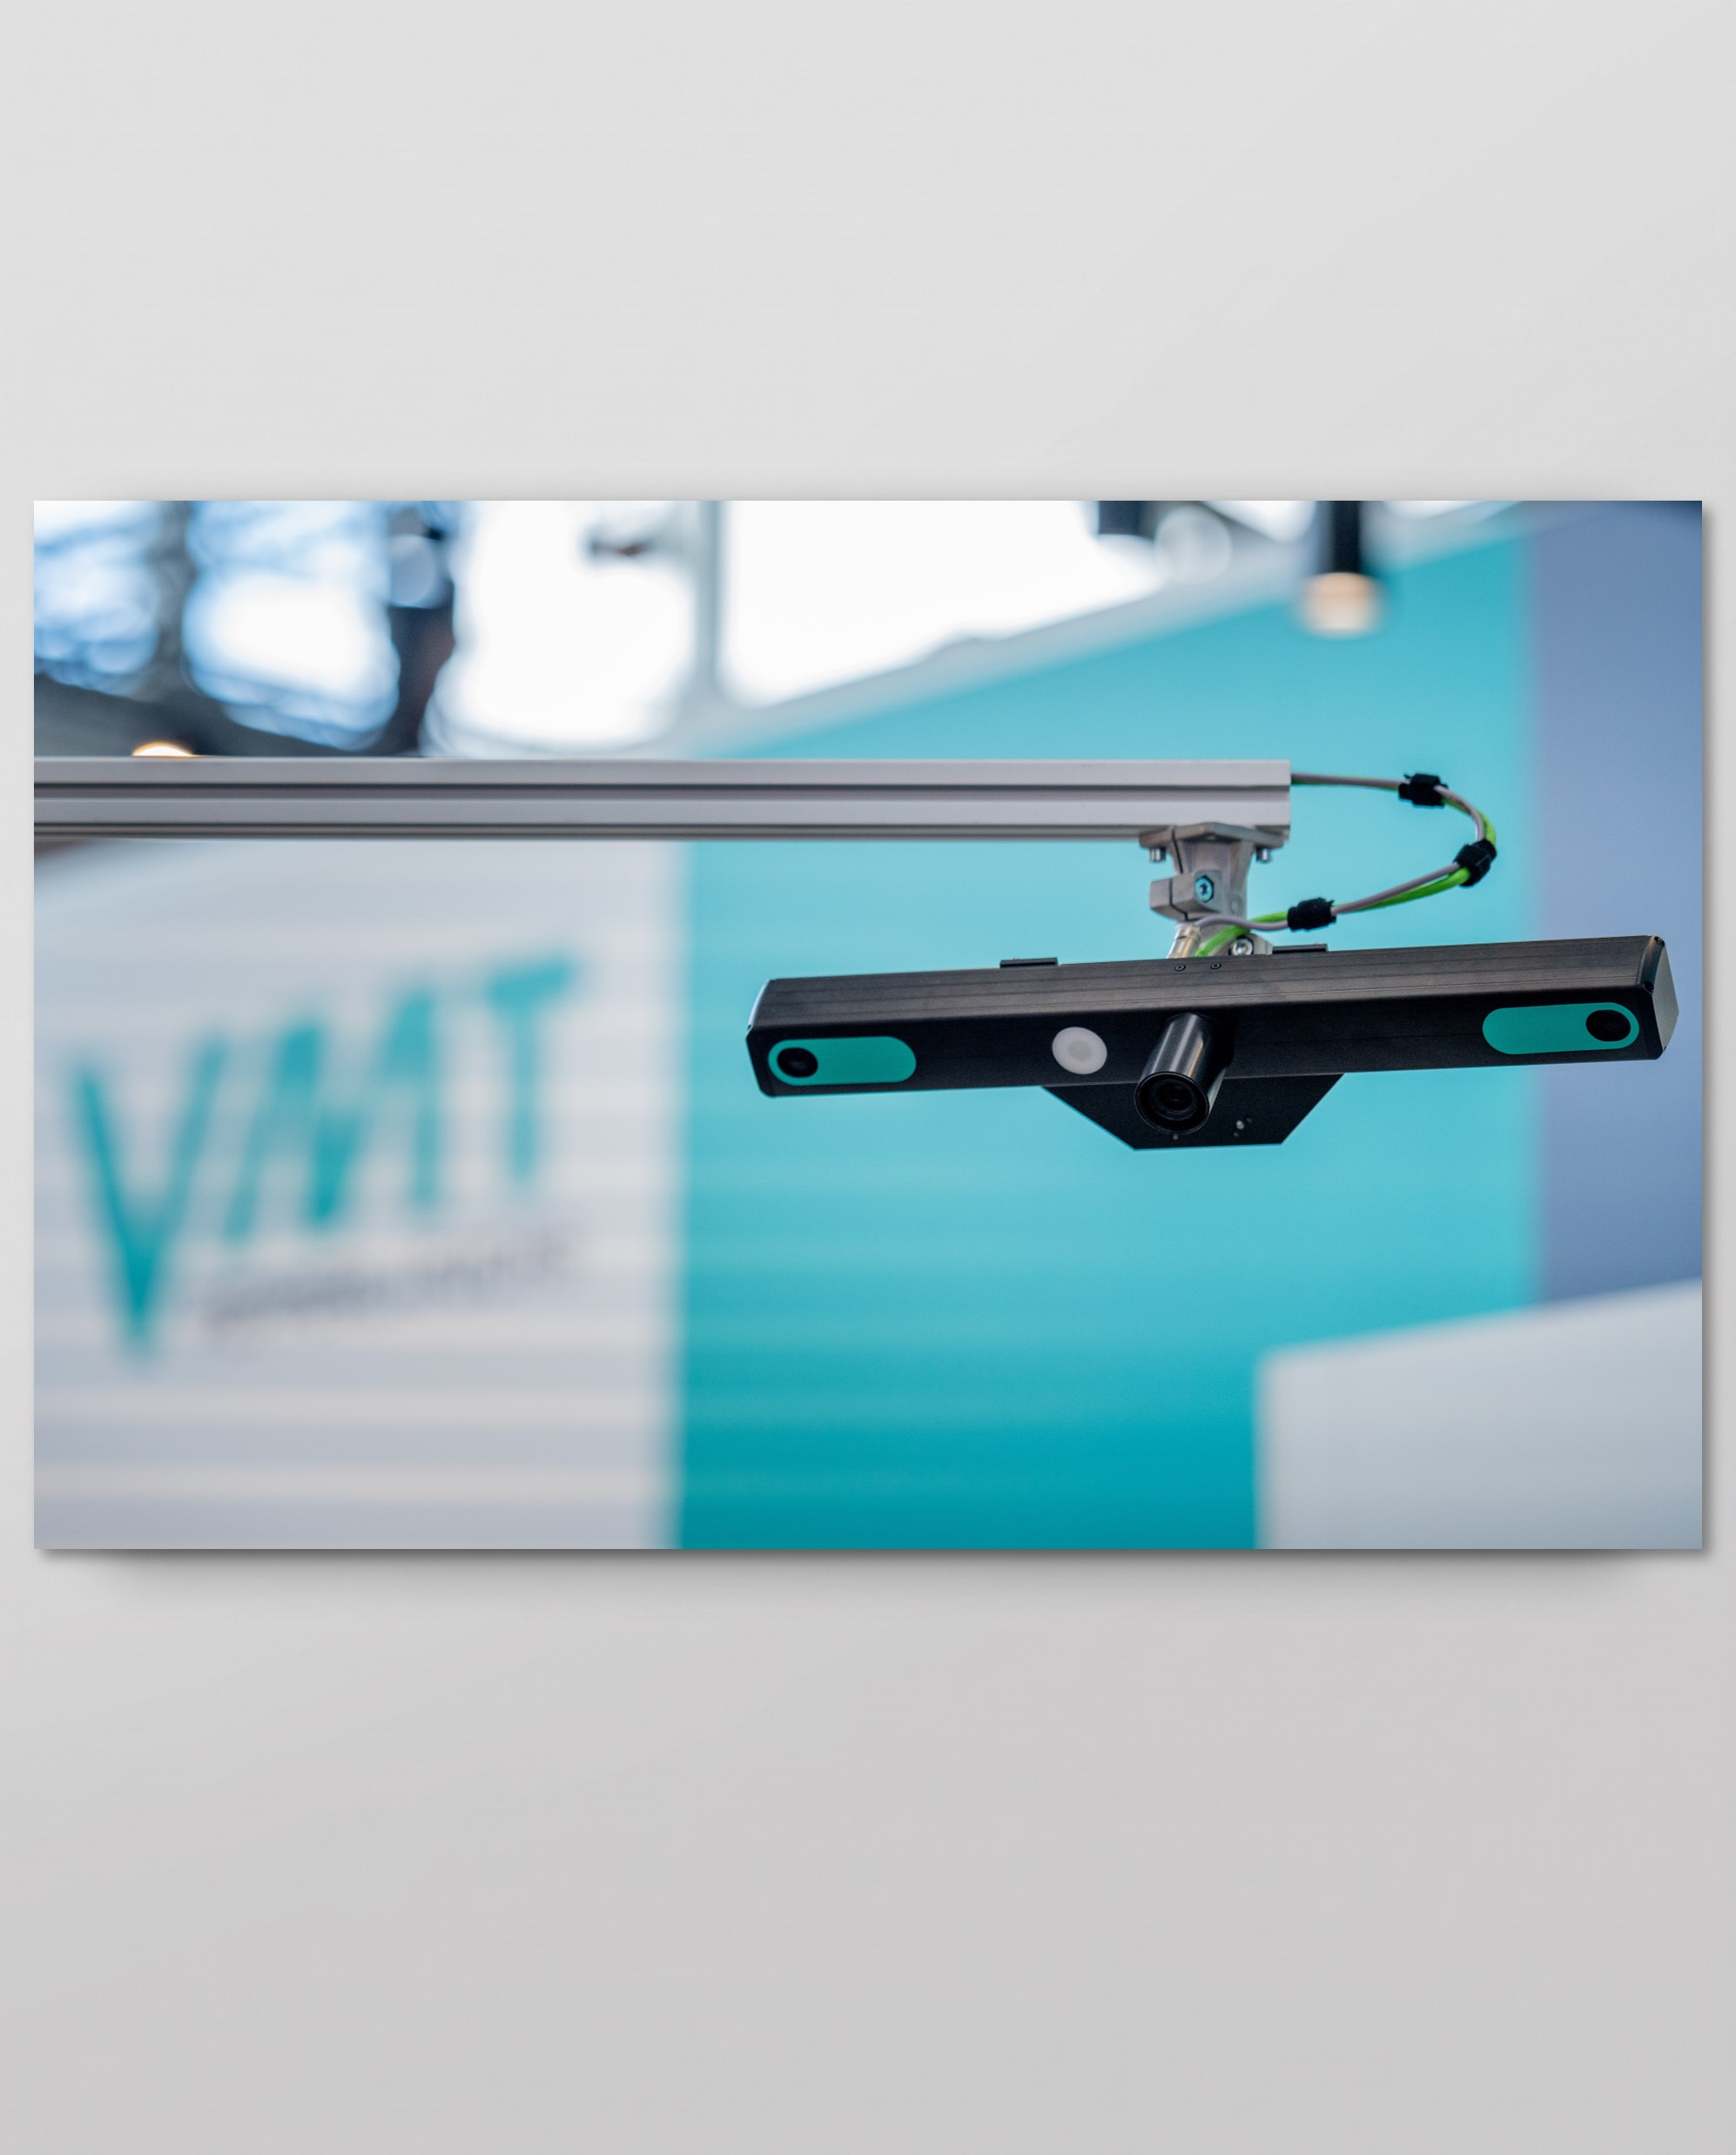
Active 3D Stereo Sensor
Projects its own pattern onto the object and uses its own illumination, ensuring reliable measurement independent of ambient light or paint color.
Robot-Guided or Static Mounting
The sensor can be robot-guided or statically mounted, with several sensors combinable for multi-angle capture.
Direct Robot Communication
Connects to a Windows IPC and communicates with the robot directly via fieldbus for fast, real-time correction data transfer.
03
Hardware & Integration
Our team will be in touch as soon as possible.
FAST RESPONSE TIMES
EXPERT CONSULTING & SUPPORT
SOLUTION-DRIVEN APPROACH
Thank you! Your submission has been received!
Oops! Something went wrong while submitting the form.