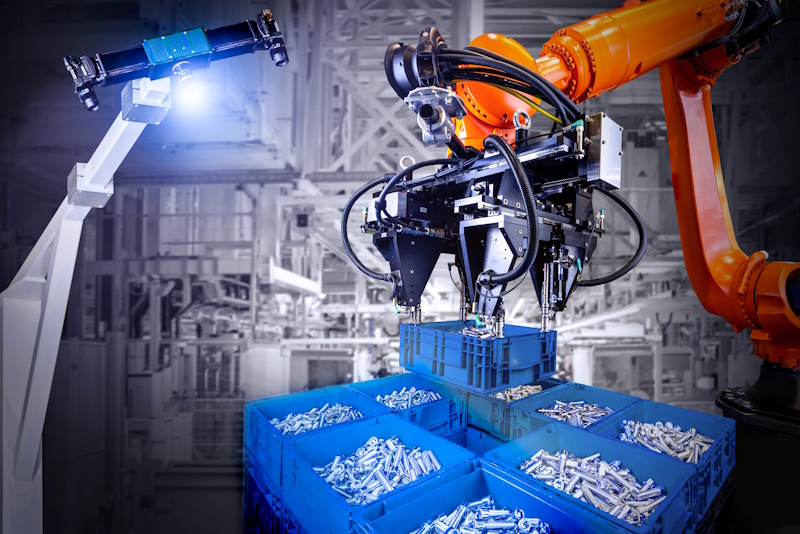
Pallets arrive mixed: different container types, sizes, colors and fill levels, no stacking scheme, no type list. VMT DeStack captures the top layer in one 3D shot, picks the best container to grip, classifies its type by AI and hands a 6D position to the robot. Fallback levels at every stage, 99.5 % availability.
8 s Cycle Time
Image capture to placement, KLT application
High-Accuracy Positioning
Container position to < 1 mm, delivered as a 6D vector
AI Type Classification
Container types identified without prior specification
How it works
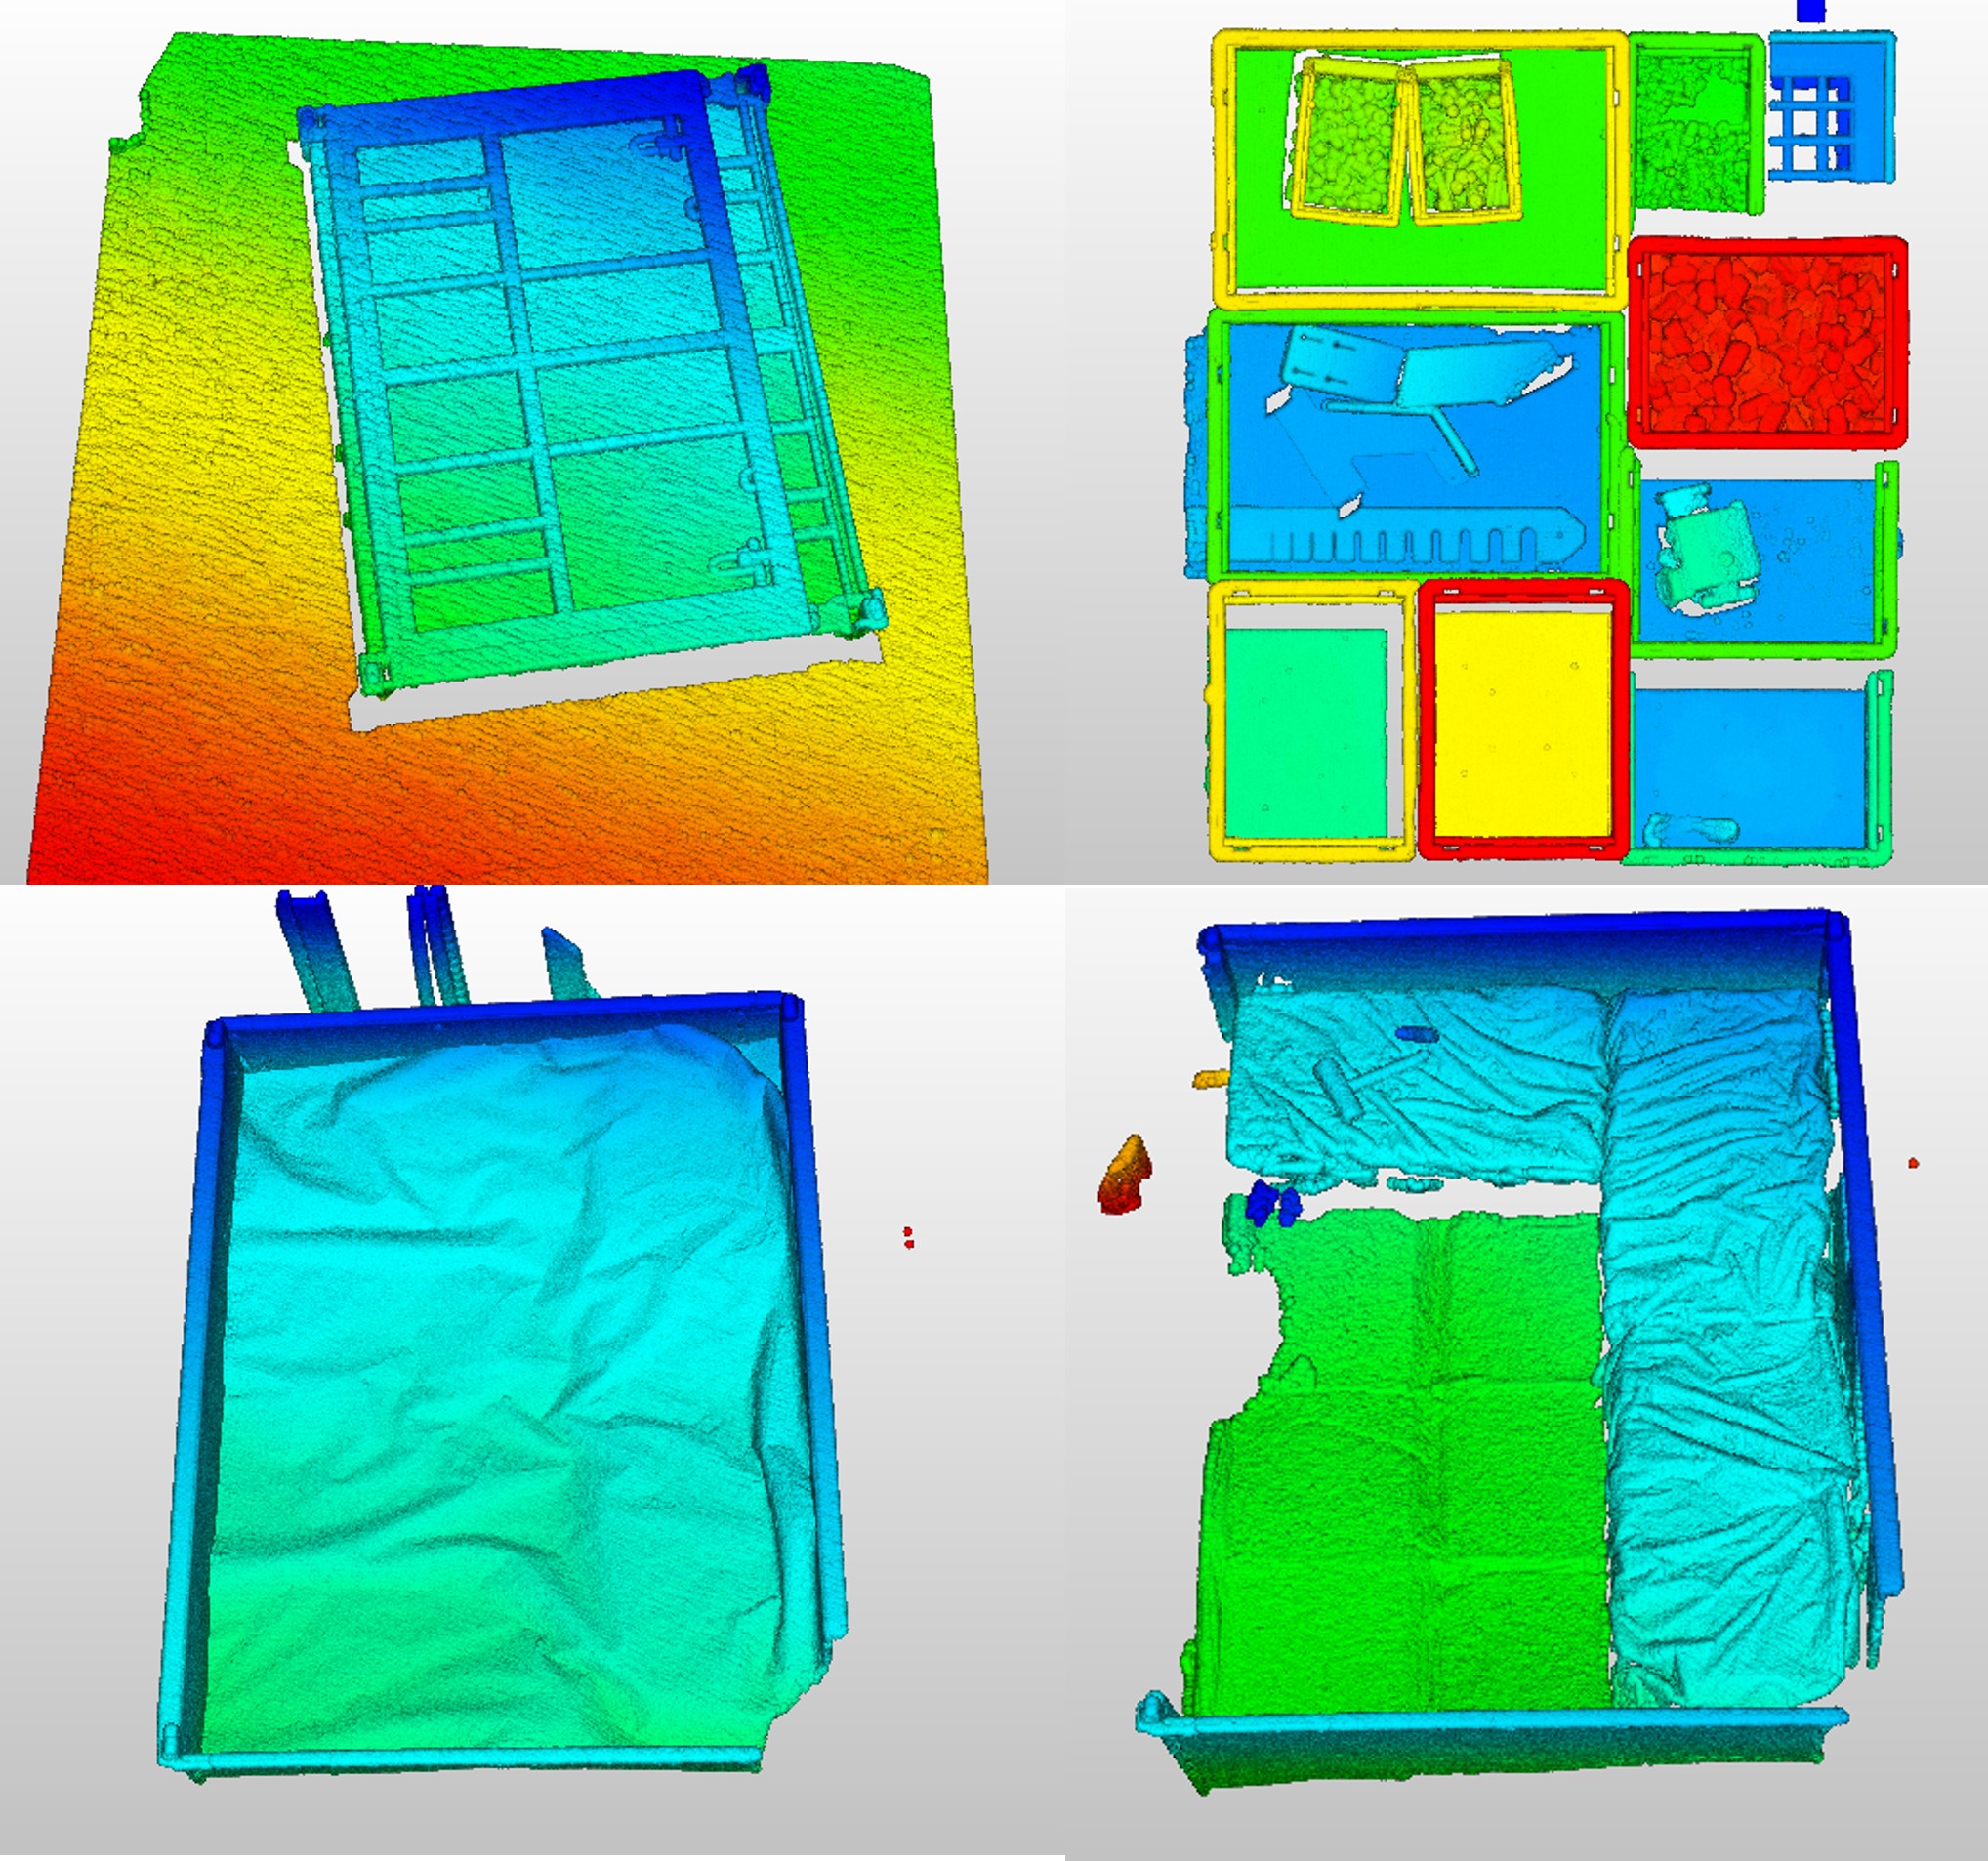
3D Point Cloud in One Shot
An active stereo sensor above the station projects patterns into the measuring volume. Its own illumination makes the measurement independent of ambient light, and exposure-time modulation captures black to white containers with one single setting. Dense point cloud at 3 m working distance.
Object Detection and AI Type Classification
The point cloud is reduced to the top layer and converted to a grey-scale image for faster processing. A defined search direction sets the depalletizing order and identifies the best container to grip. AI then determines the container type from inner surface, side lengths and hole pattern.
6D Position and Fallback Levels
Type and position are validated against the hole spacing, with a bundle adjustment across the individual features. Three of four holes are enough, and container distortion is tolerated. Output: X, Y, Z, RX, RY, RZ. Each processing stage has its own fallback level, covering partially occluded containers, unconfirmed types, excessively tilted containers and objects detected inside the gripping holes.
01
How it works
Software & Control
Built on VMT MSS
The application runs on the VMT MSS software platform and can be extended with project-specific checks without touching the core process.
Configurable Depalletizing Sequence
Search direction and picking order are freely defined, front to back or top to bottom, matching the downstream conveyor and gripper.
Extended Checks
Lid type and position, container fill level, empty containers, empty pallets, and label position via a separate 2D camera for correct orientation on the conveyor.
02
Software & Control
Hardware & Integration
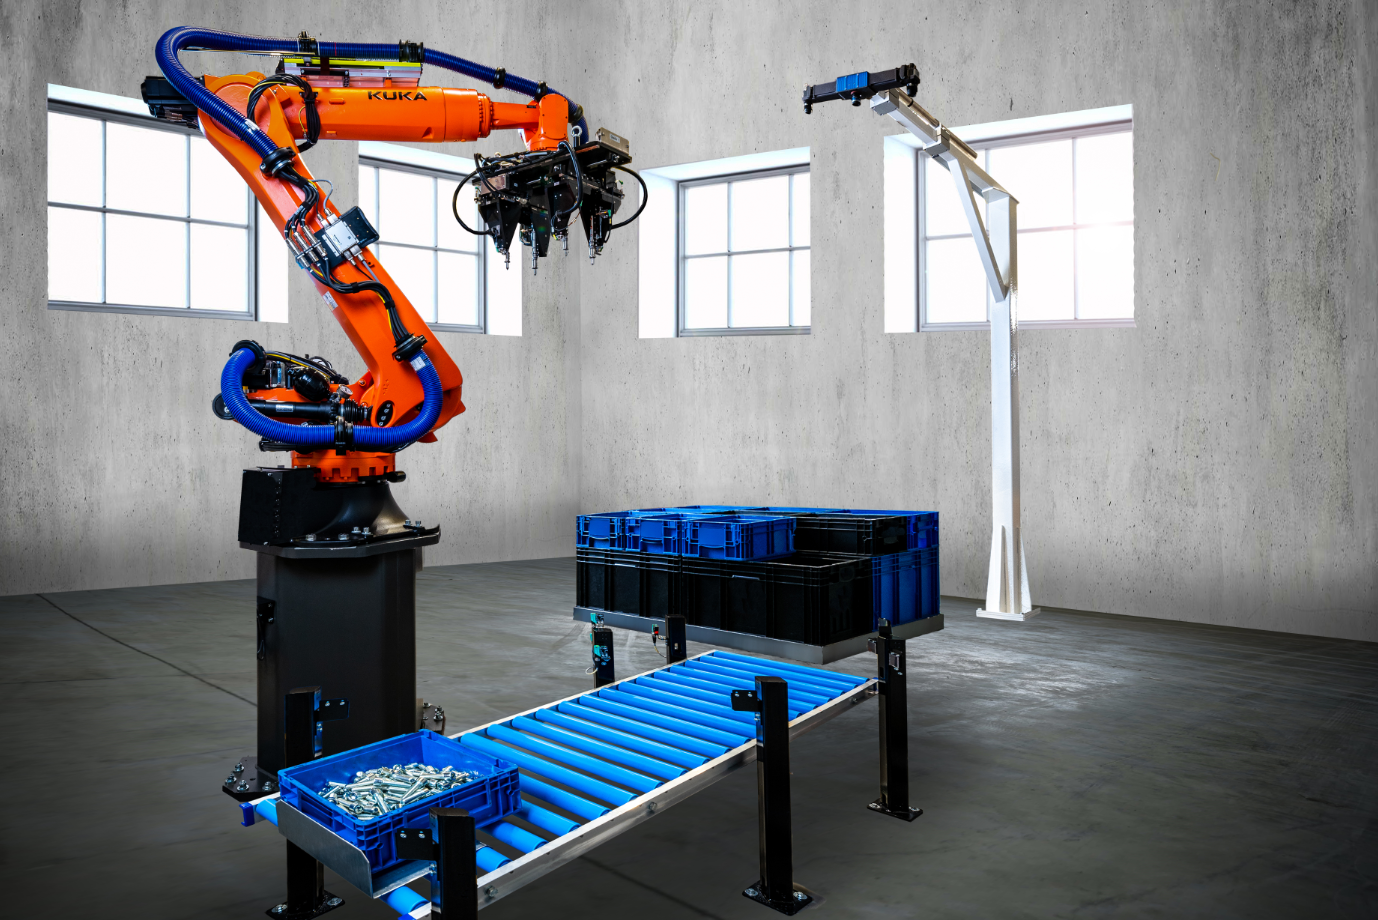
One Stationary 3D Sensor
A single sensor above the station covers the full depalletizing area. No sensor on the robot, no in-cycle recalibration, no second measuring step.
Gripper with Crash Protection
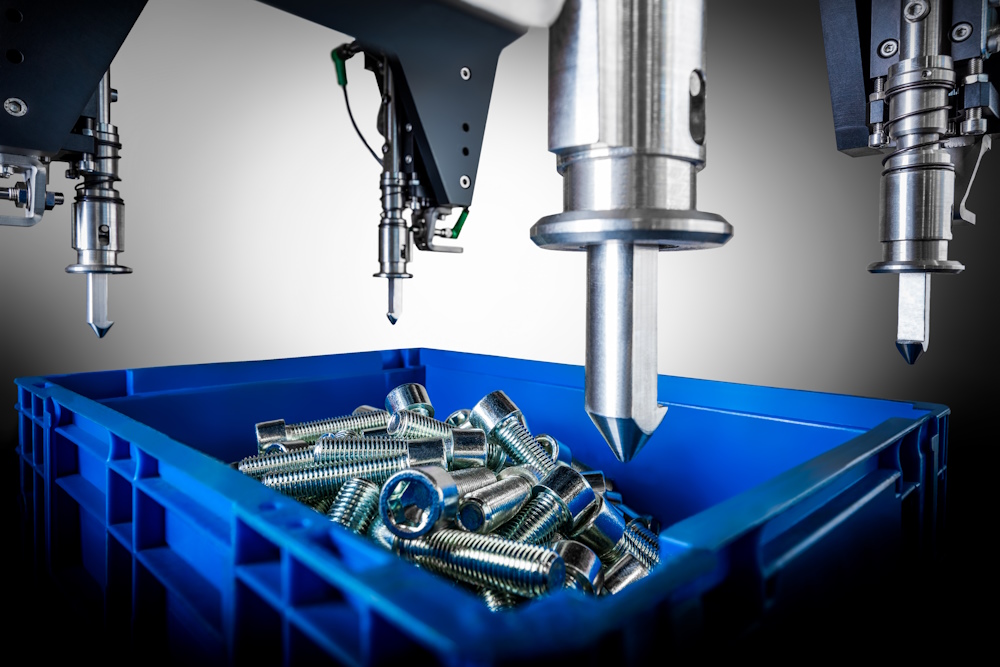
Gripper developed for load carriers, gripping vertically into the container holes, up to 25 kg. Sensors monitor finger travel and confirm engagement, so tilted containers or objects inside a gripping hole are detected before the gripper is damaged.
Direct Robot Interface
Windows IPC with a direct sensor link, fieldbus communication straight to the robot, technology packages available for KUKA, ABB and Fanuc.
03
Hardware & Integration
Our team will be in touch as soon as possible.
FAST RESPONSE TIMES
EXPERT CONSULTING & SUPPORT
SOLUTION-DRIVEN APPROACH
Thank you! Your submission has been received!
Oops! Something went wrong while submitting the form.